 Innok Robotics
Customer Interview: How provita medical Masters Intralogistics at a Brownfield Site
The Latest Innok Case Study: INDUROS Automates Cross-Plant Logistics at provita medical
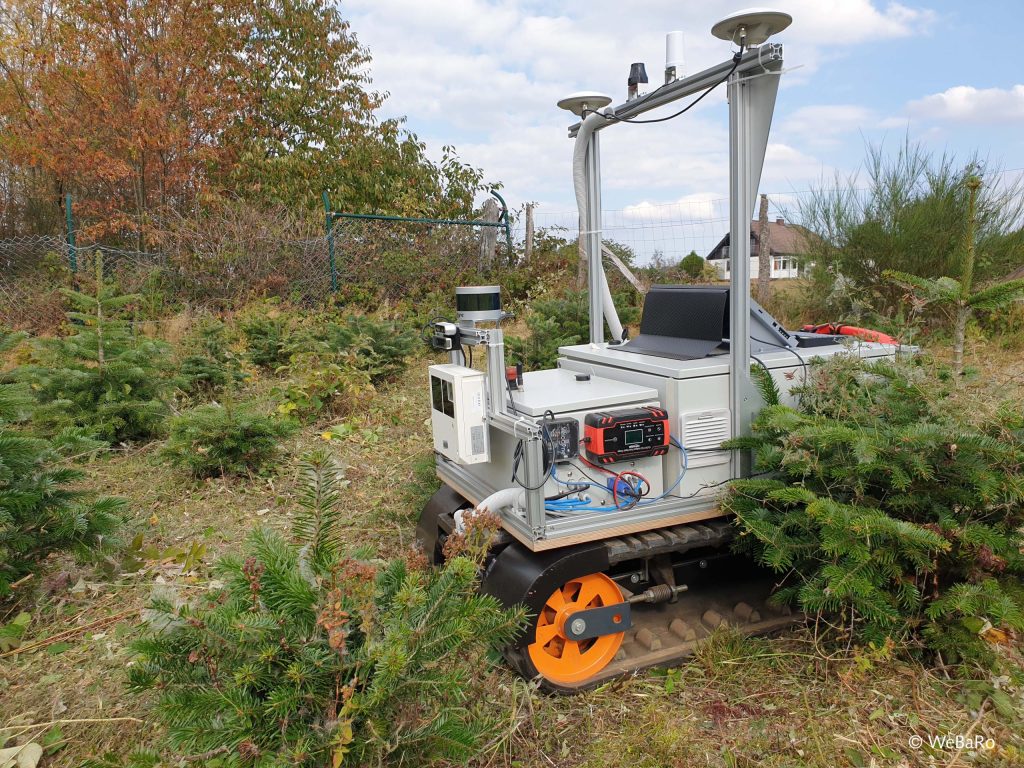
Conventional Christmas tree cultivation is very labour-intensive and is also characterized by a high use of pesticides during cultivation. In terms of sustainable and economical cultivation, both factors can be seen as a major challenge.
In order to meet these challenges, the WeBaRo project is developing and testing a cost-effective, autonomous robot carrier platform that enables resource-conserving, efficient Christmas tree cultivation.
Virtual map with georeferenced tree positions
To plant the seedlings, the platform is equipped with a planting hole drill. The exact position of the planting holes is calculated area-specifically by an algorithm; these can then be drilled with centimeter accuracy and georeferenced.
As a result of this procedure, a virtual map with georeferenced tree positions is created - the basis for satellite-controlled navigation for all further autonomous work in the crop.

The Latest Innok Case Study: INDUROS Automates Cross-Plant Logistics at provita medical
Innok Robotics GmbH Expands Executive Management: Michael Hanselmann Joins as Chief Financial Officer (CFO) Ahead of Planned Initial Public Offering
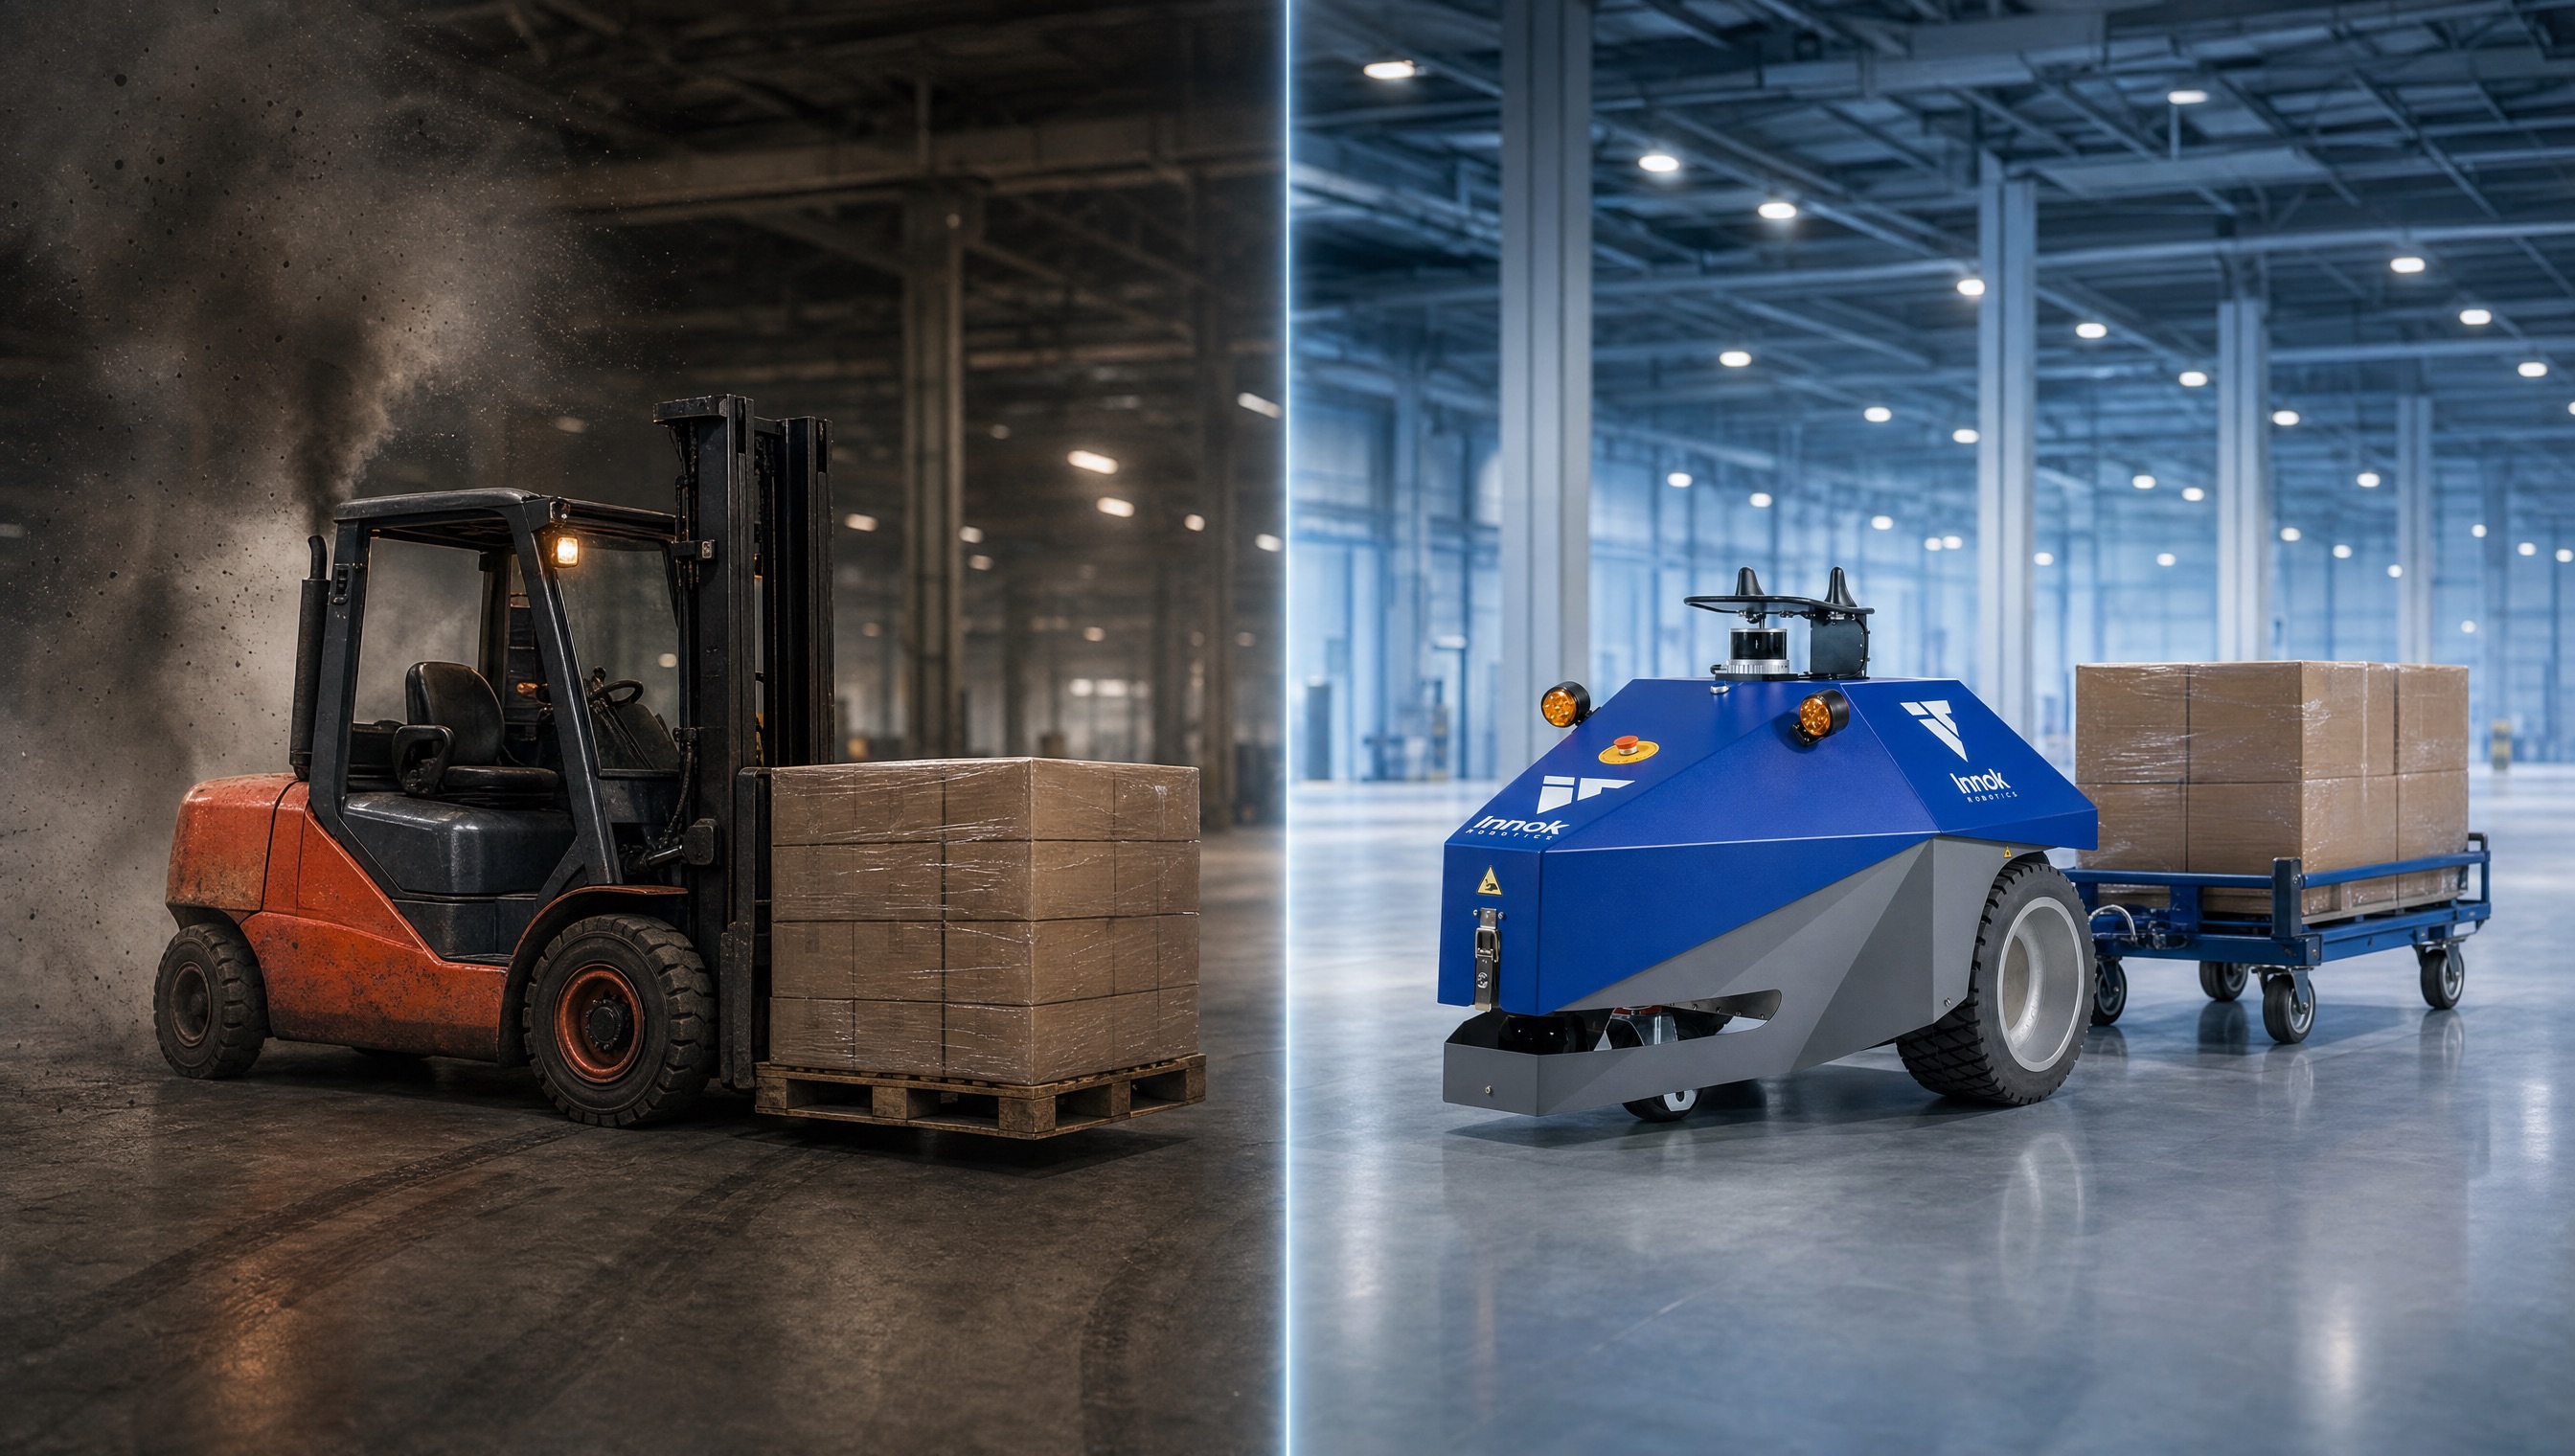
Reducing CO2 Emissions in Intralogistics: Where Emissions Occur and How Much Automation Really HelpsEmission factors, calculation examples, and...